PSE

Panel Mount Hall-Effect Rotary Sensor

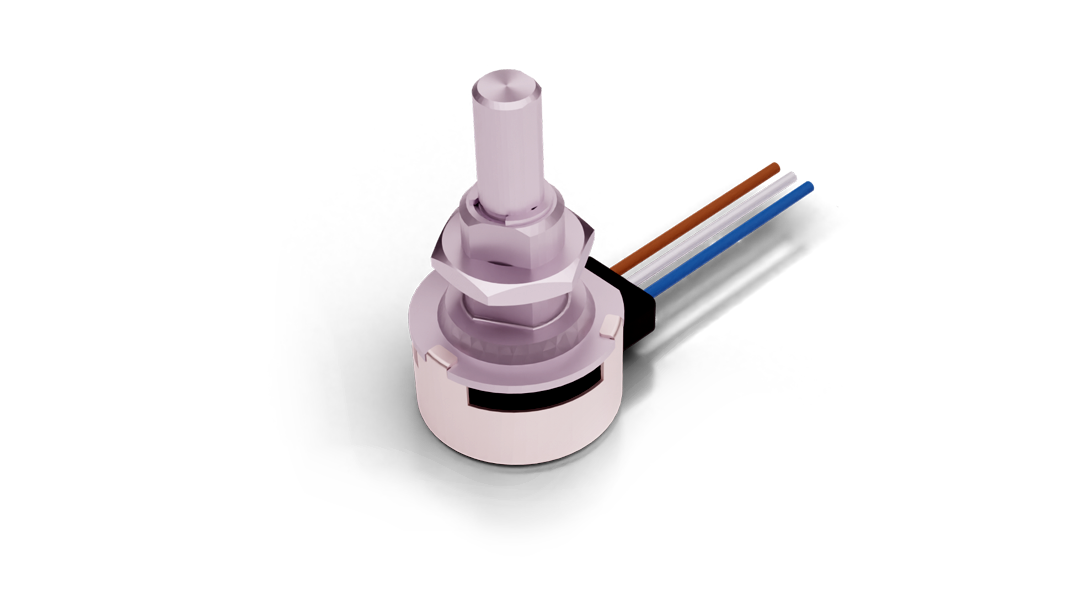
The PSE Series Rotary Position Sensors are based on contactless hall-effect technology and deliver high accuracy and linearity in a compact package. Increased rotational life and robustness against humidity, vibration and shock make them perfectly suited for harsh industrial and transportation environments. These absolute sensors will not lose their position values, even after a power failure.

The PSE end-of-shaft sensor is is available in two versions: one featuring 360-degree continuous rotation with programmable electrical angles from 15° to 360° (without deadband), and another with a mechanical stop limiting rotational travel to 290°.

Custom versions with different shafts and customer-specific output curves are available upon request.

KEY FEATURES


Without any gears or mechanical interfaces the sensor is easily assembled and calibrated and subject to limited wear and tear over lifetime.
The magnet is securely fastened to the shaft and acts as only moving component in the sensor.
The rugged package protects the sensor from dust, moisture, vibration and extreme temperatures for usage in the most demanding environments.
Programmable transfer function and switch outputs as well as different output protocols and redundancy levels available


SPECIFICATIONS


Linearity ±1% absolute (±0.5% upon request)
Electrical Angular Range** 360°, 270°, 180°, 120°, 90°, 50°
Output Protocol Analog (Ratiometric), PWM
Resolution 12 bits
Output Range** standard - 10% to 90% Vdc
inverted - 90% to 10% Vdc
Supply Voltage** 5V ±10%
Supply Current Typ 8.5 mA
Voltage Protection ±18V
Self-diagnostic features yes

** Other specification on request. For electrical angular ranges below 50º: check availability.

Mechanical Angular Range* 360° endless rotation (PSE-360)
290º (PSE-290)
Connection Fly leads, connector assembly on request
Shaft diameter 6.25 mm
Mounting Method Panel mount
Life (cycles) 50.000.000

* Other specifications on request

POTENTIAL APPLICATIONS


DOWNLOADS


CONFIGURATOR


    Configure

    /@ output-signal:Full-redundant; supply-voltage("7V to 15V") @/ /@ output-protocol:Analog; pwm-frecuency("FXXX") @/ /@ output-protocol:Analog; pwm-frecuency("F250") @/ /@ output-protocol:Analog; supply-voltage("7V to 32V") @/ /@ output-protocol:PWM; supply-voltage("7V to 32V") @/ /- electrical-angle:electrical-angle -/ /- rotation:rotation -/ /- magnet-model:magnet-model -/ /- magnet-position:magnet-position -/ /- supply-voltage:supply-voltage -/ /- output-protocol:output-protocol -/ /- supply-voltage:supply-voltage -/ /$ %func% () $/ /$ %v% () $/ /$ %output% () $/ /$ %type% (1) $/ /$ %era% (XXX) $/ /$ %pwmf% () $/ /- pwm-frecuency:pwm-frecuency -/ /@ rotation:290; electrical-angle("360º" "180º" "120º" "90º" "50º") @/ /@ output-protocol:Analog; pwm-frecuency("FXXX") @/ /@ output-protocol:Analog; pwm-frecuency("F250") @/ /? output-protocol:PWM; (-F250) %pwmf% ?/ /? output-signal:standard; (S) %func% ?/ /? output-signal:inverted; (I) %func% ?/ /? supply-voltage:05K; (05) %v% ?/ /? output-protocol:PWM; (P) %output% ?/ /? output-protocol:Analog; (A) %output% ?/ /% PSE*rotation*-%output%-ERA*electrical-angle*%func%-05%pwmf% %/